
Drivetrain Concept Documentation
This page outlines the design, analysis, and selection process for the mobility systems of two autonomous rover platforms: Hyperion and Theia. These drivetrain concepts are optimized for their respective terrains and mission objectives, integrating advanced engineering principles to ensure efficiency, durability, and adaptability in challenging environments.
Hyperion: Tank-Style Rover
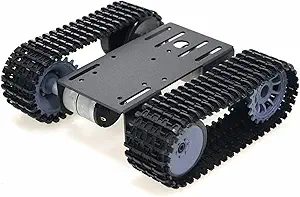
Hyperion, designed for rugged and high-resistance terrain, utilizes a continuous tread system to maximize traction, stability, and weight distribution. The treads provide superior performance in loose soil, sand, and rocky surfaces, reducing ground pressure and increasing maneuverability.
Concept Evaluation
This concept evaluation provides a structured methodology for selecting the most efficient mobility system for Hyperionand Theia, considering performance, durability, and mission-specific requirements. A decision matrix was used to evaluate key factors influencing the choice between purchased treads/wheels and 3D-printed treads/wheels for both rover platforms.
Concept Evaluation Criteria
To ensure optimal drivetrain selection, the following weighted criteria were analyzed:
- Price (25%): Cost-effectiveness of manufacturing or procuring components.
- Effort (25%): Complexity of integrating and assembling the drivetrain.
- Reliability (37.5%): Structural integrity and durability of the treads or wheels in demanding environments.
- Customizability (12.5%): Ability to tailor the design for specific terrains and operational needs.
Decision Matrix
| Category | Weighting | Purchased Treads/Wheels | 3D Printed Treads/Wheels |
|---|---|---|---|
| Price | 0.25 | 0 | 1 |
| Effort | 0.25 | 1 | 0 |
| Reliability | 0.375 | 1 | 0 |
| Customizability | 0.125 | 0 | 1 |
| Totals | 1 | 0.625 | 0.375 |
Final Decision & Implementation
The final weighting and analysis results determined that purchased treads/wheels scored higher in overall reliability and assembly effort, while 3D-printed treads/wheels offered advantages in price and customizability. Given the mission needs of each rover:
- Hyperion (Tank-Style Rover): Will utilize purchased treads to ensure maximum durability and reliability in challenging terrain.
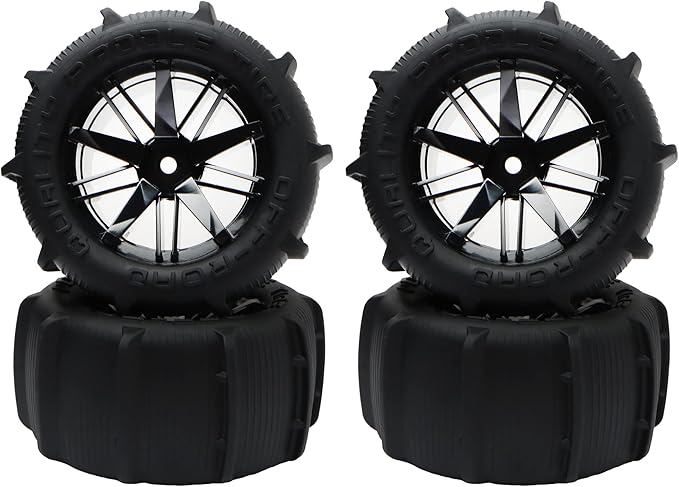
- Theia (Car-Style Rover): Will leverage purchased paddle wheels to meet current assigned mission requirements.
These selections optimize mission success, structural integrity, and cost efficiency, ensuring that both Hyperion and Theia can perform effectively in their respective environments.
Visual Reference
Purchased Treads (Hyperion)
Purchased Wheels (Theia)
Hyperion Tread Tensioner
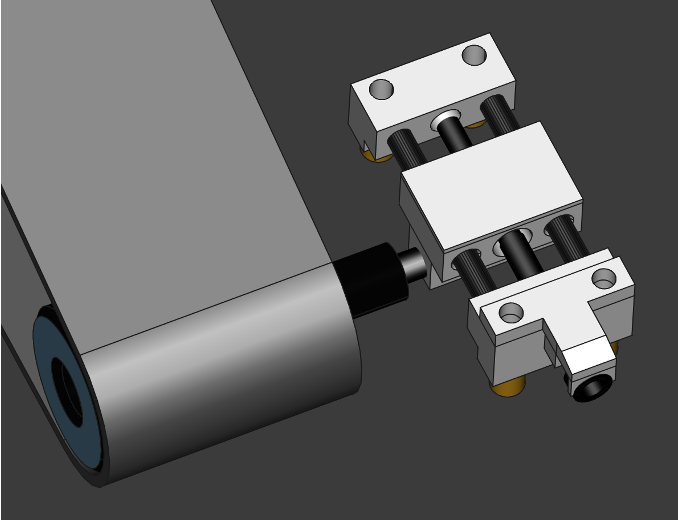
The final analysis and testing results confirmed that the selected tread tensioner design for Hyperion best meets the mission requirements by maintaining optimal tread tension, reducing slippage, and improving overall drivetrain efficiency. The system ensures consistent performance across various terrain types.
- Hyperion (Tank-Style Rover): Will use an adjustable spring-loaded tensioner, allowing for real-time compensation for tread slack and wear, ensuring smooth operation in rough environments.
This implementation increases durability, enhances mobility, and prevents drivetrain failures, ensuring long-term reliability for Hyperion’s missions.
Hyperion Tread Tensioner
Hyperion Motor Shield
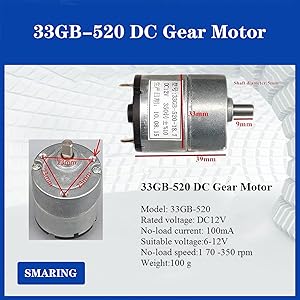
Hyperion Motor